Changhe Chen

CS Ph.D. student at Northwestern University

personal_images/1.jpg

Northwestern University

Evanston, Illinois

changhec@u.northwestern.edu

I am a CS Ph.D. student at Northwestern University, co-advised by Prof. Manling Li and Prof. Ruohan Zhang. Before Northwestern, I received my M.S. in Robotics from the University of Michigan, where I was advised by Prof. Nima Fazeli and Prof. Xiaonan (Sean) Huang. Prior to Michigan, I received my BASc in Electrical Engineering from the University of Toronto, where I worked with Prof. Chan Carusone on reinforcement learning for analog circuit design. In summer 2025, I collaborated on robotics research and real-world robotic systems with Prof. Heng Yang’s group at Harvard University.

My current research focuses on embodied AI, data-efficient robot learning, and learning from humans, with an emphasis on multimodal vision-language models and instruction-based semantic segmentation for robotic understanding and execution of complex tasks.

I am open to collaboration. If you have an idea, project, or research direction you would like to discuss, please feel free to contact me by email.

selected publications (*† indicates equal contribution)
  1. RSS
    MoTVLA.png
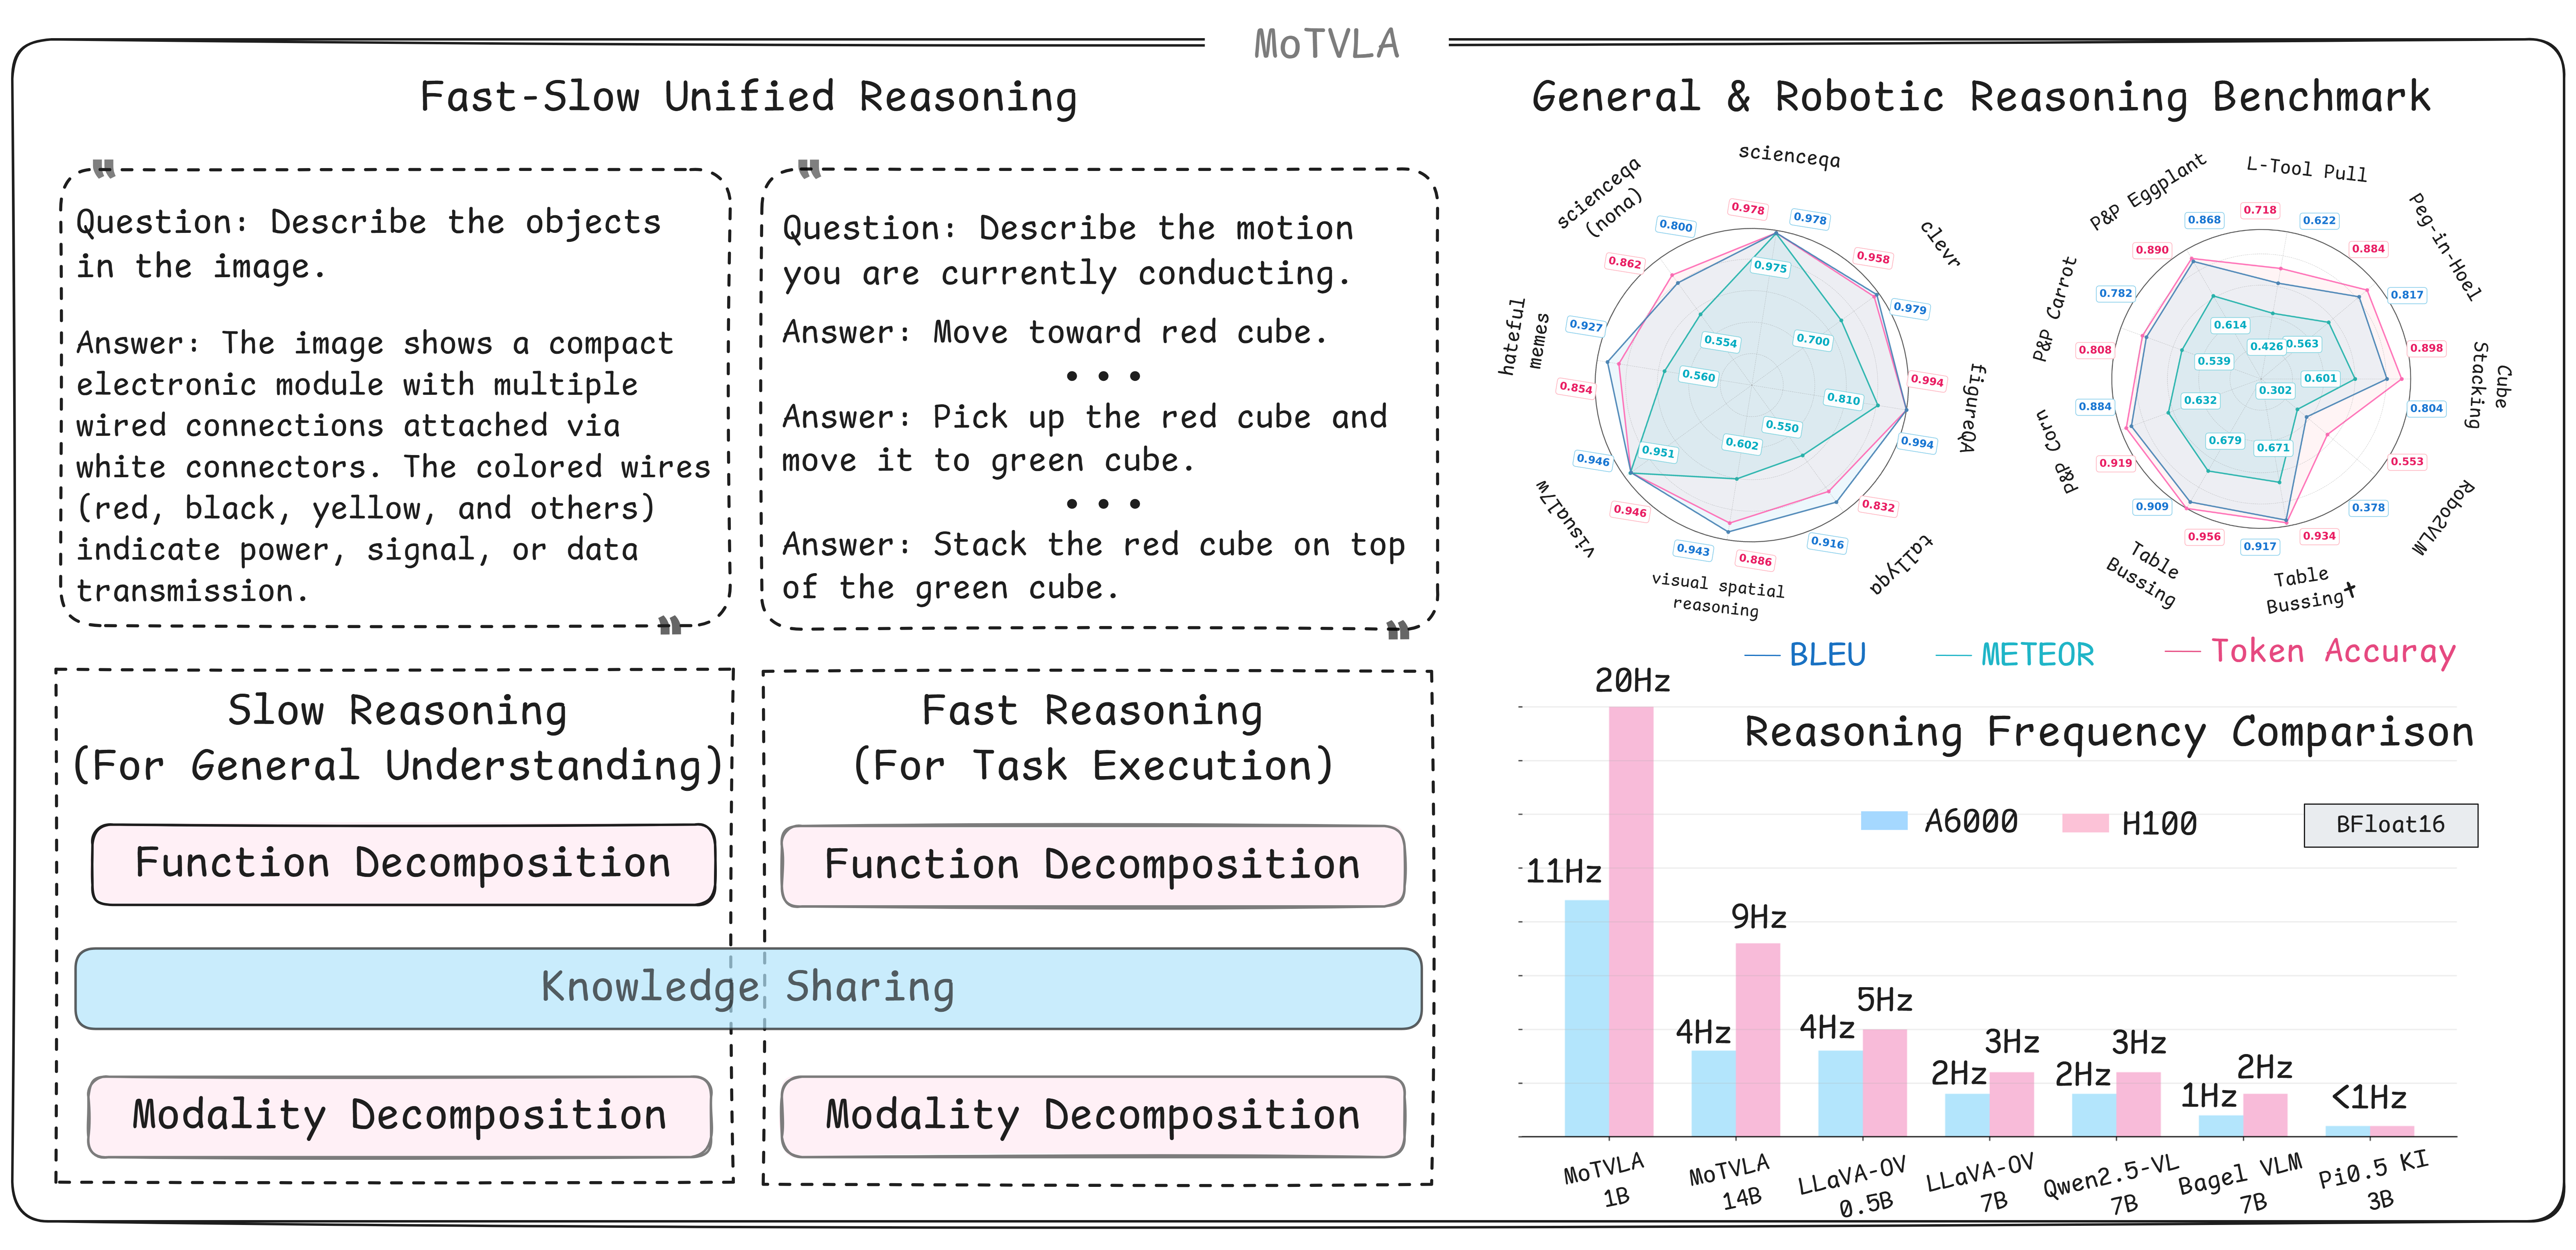
    MoTVLA: A Vision-Language-Action Model with Unified Fast-Slow Reasoning
    Wenhui Huang*, Changhe Chen*, Han Qi, Lv Chen, Yilun Du, and Heng Yang
    Robotics: Science and Systems (RSS), 2026
    under review
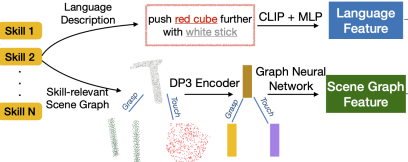
  2. Compose by Focus: Scene Graph-based Atomic Skills
    Han Qi, Changhe Chen, and Heng Yang
    In IEEE International Conference on Robotics and Automation (ICRA), 2026
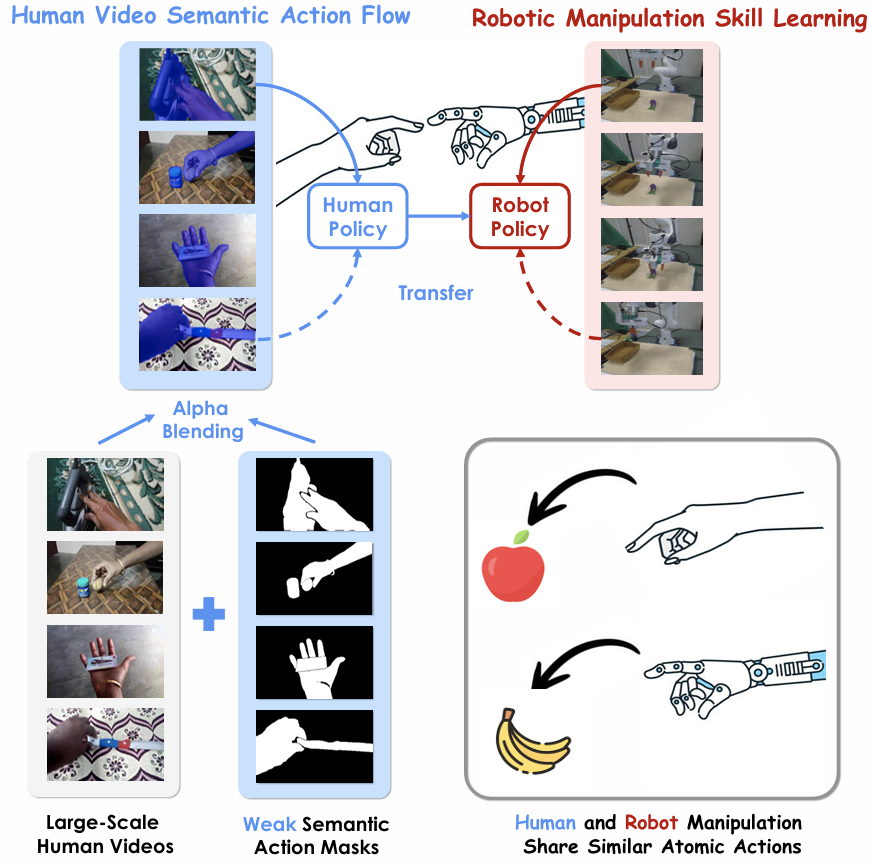
  3. ViSA-Flow: Accelerating Robot Skill Learning via Large-Scale Video Semantic Action Flow
    Changhe Chen*, Quantao Yang*, Xiaohao Xu, Nima Fazeli, and Olov Andersson
    In IEEE International Conference on Robotics and Automation (ICRA), 2026
    EgoAct workshop, Robotics: Science and Systems (RSS) 2025
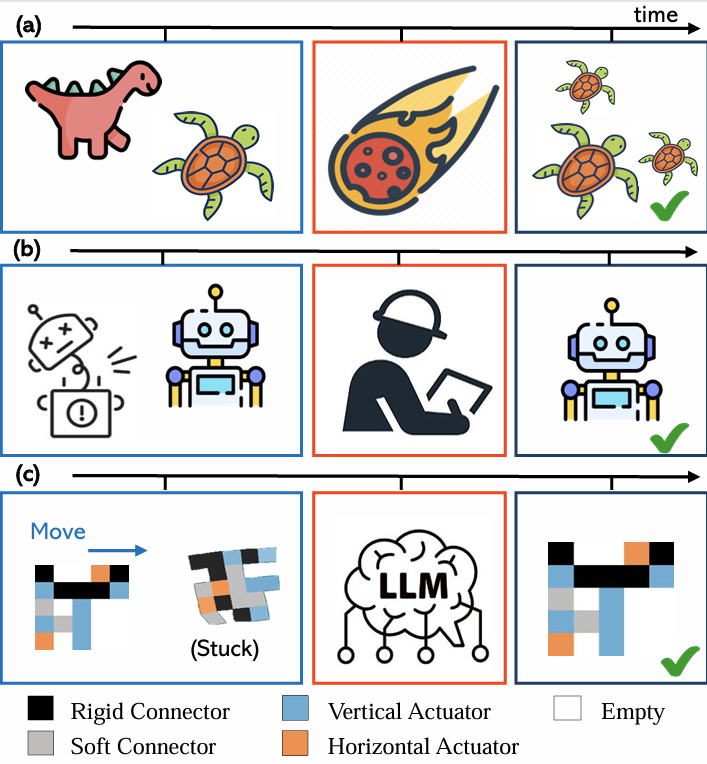
  4. Natural Selection via Foundation Models for Soft Robot Evolution
    Changhe Chen*, Xiaohao Xu*, Xiangdong Wang*, Jiaqi Wang, and Xiaonan Huang
    IEEE International Conference on Soft Robotics (RoboSoft), 2026
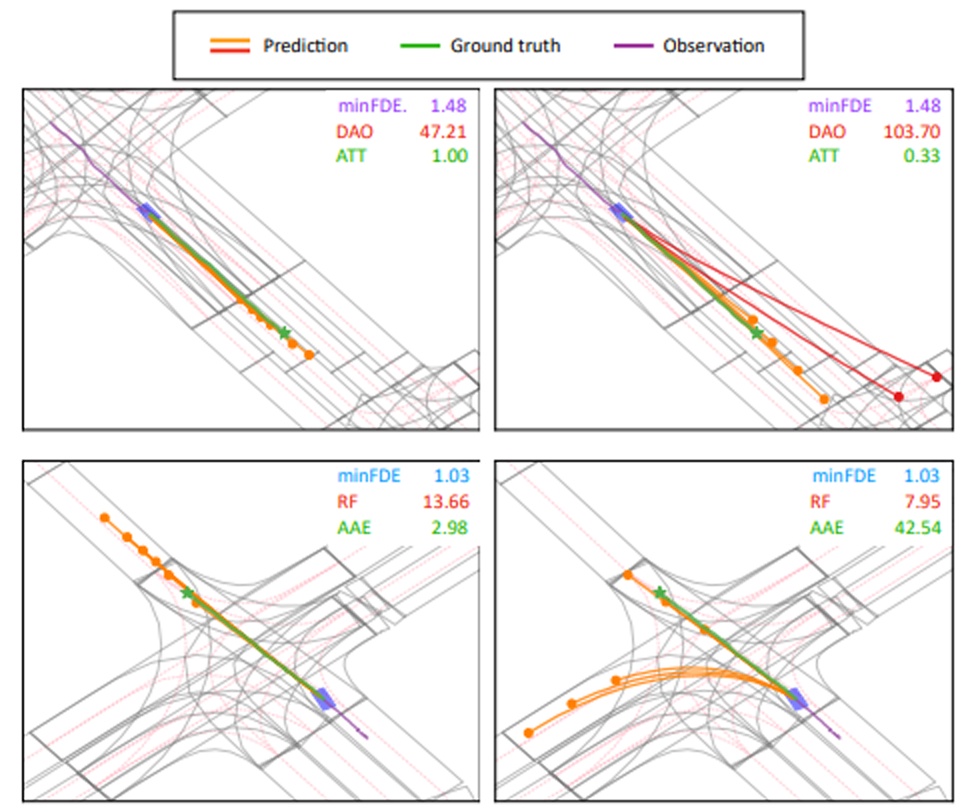
  5. CRITERIA: A New Benchmarking Paradigm to Evaluate Trajectory Prediction Approaches
    Changhe Chen, Mozhgan Pourkeshavarz, and Amir Rasouli
    In IEEE International Conference on Robotics and Automation (ICRA), 2024
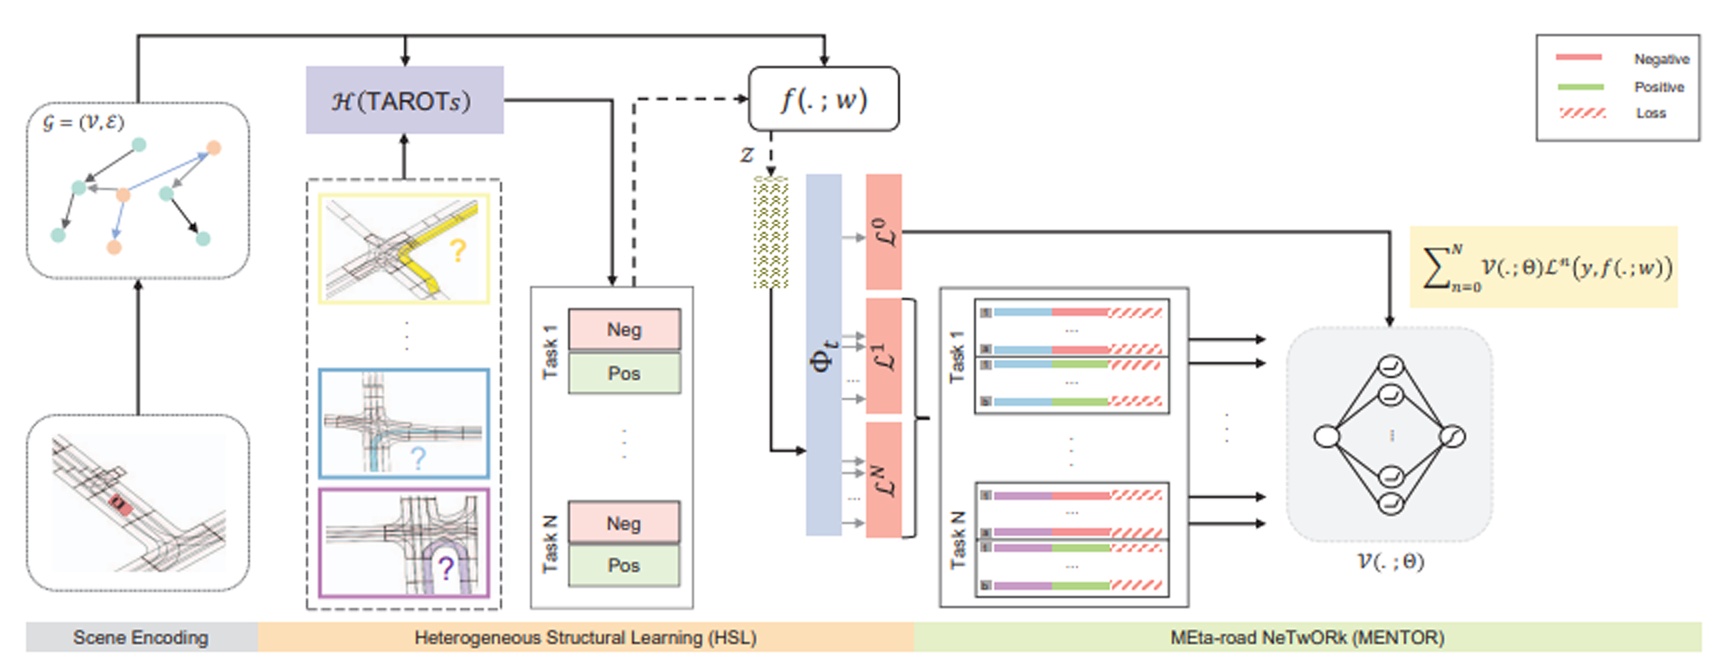
  6. Learn TAROT with MENTOR: A Meta-Learned Self-Supervised Approach for Trajectory Prediction
    Mozhgan Pourkeshavarz, Changhe Chen, and Amir Rasouli
    In Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV), 2023

awards & service

Academic Service

  • Reviewer, ICRA
  • Reviewer, IROS

Selective Awards

  • 2020 Fall/Winter Dean's Honours List
  • 2021 Fall/Winter Dean's Honours List
  • 2022 Winter Dean's Honours List
  • 2023 Fall Dean's Honours List
  • 2024 Winter Dean's Honours List
  • 2024 Graduation with honors