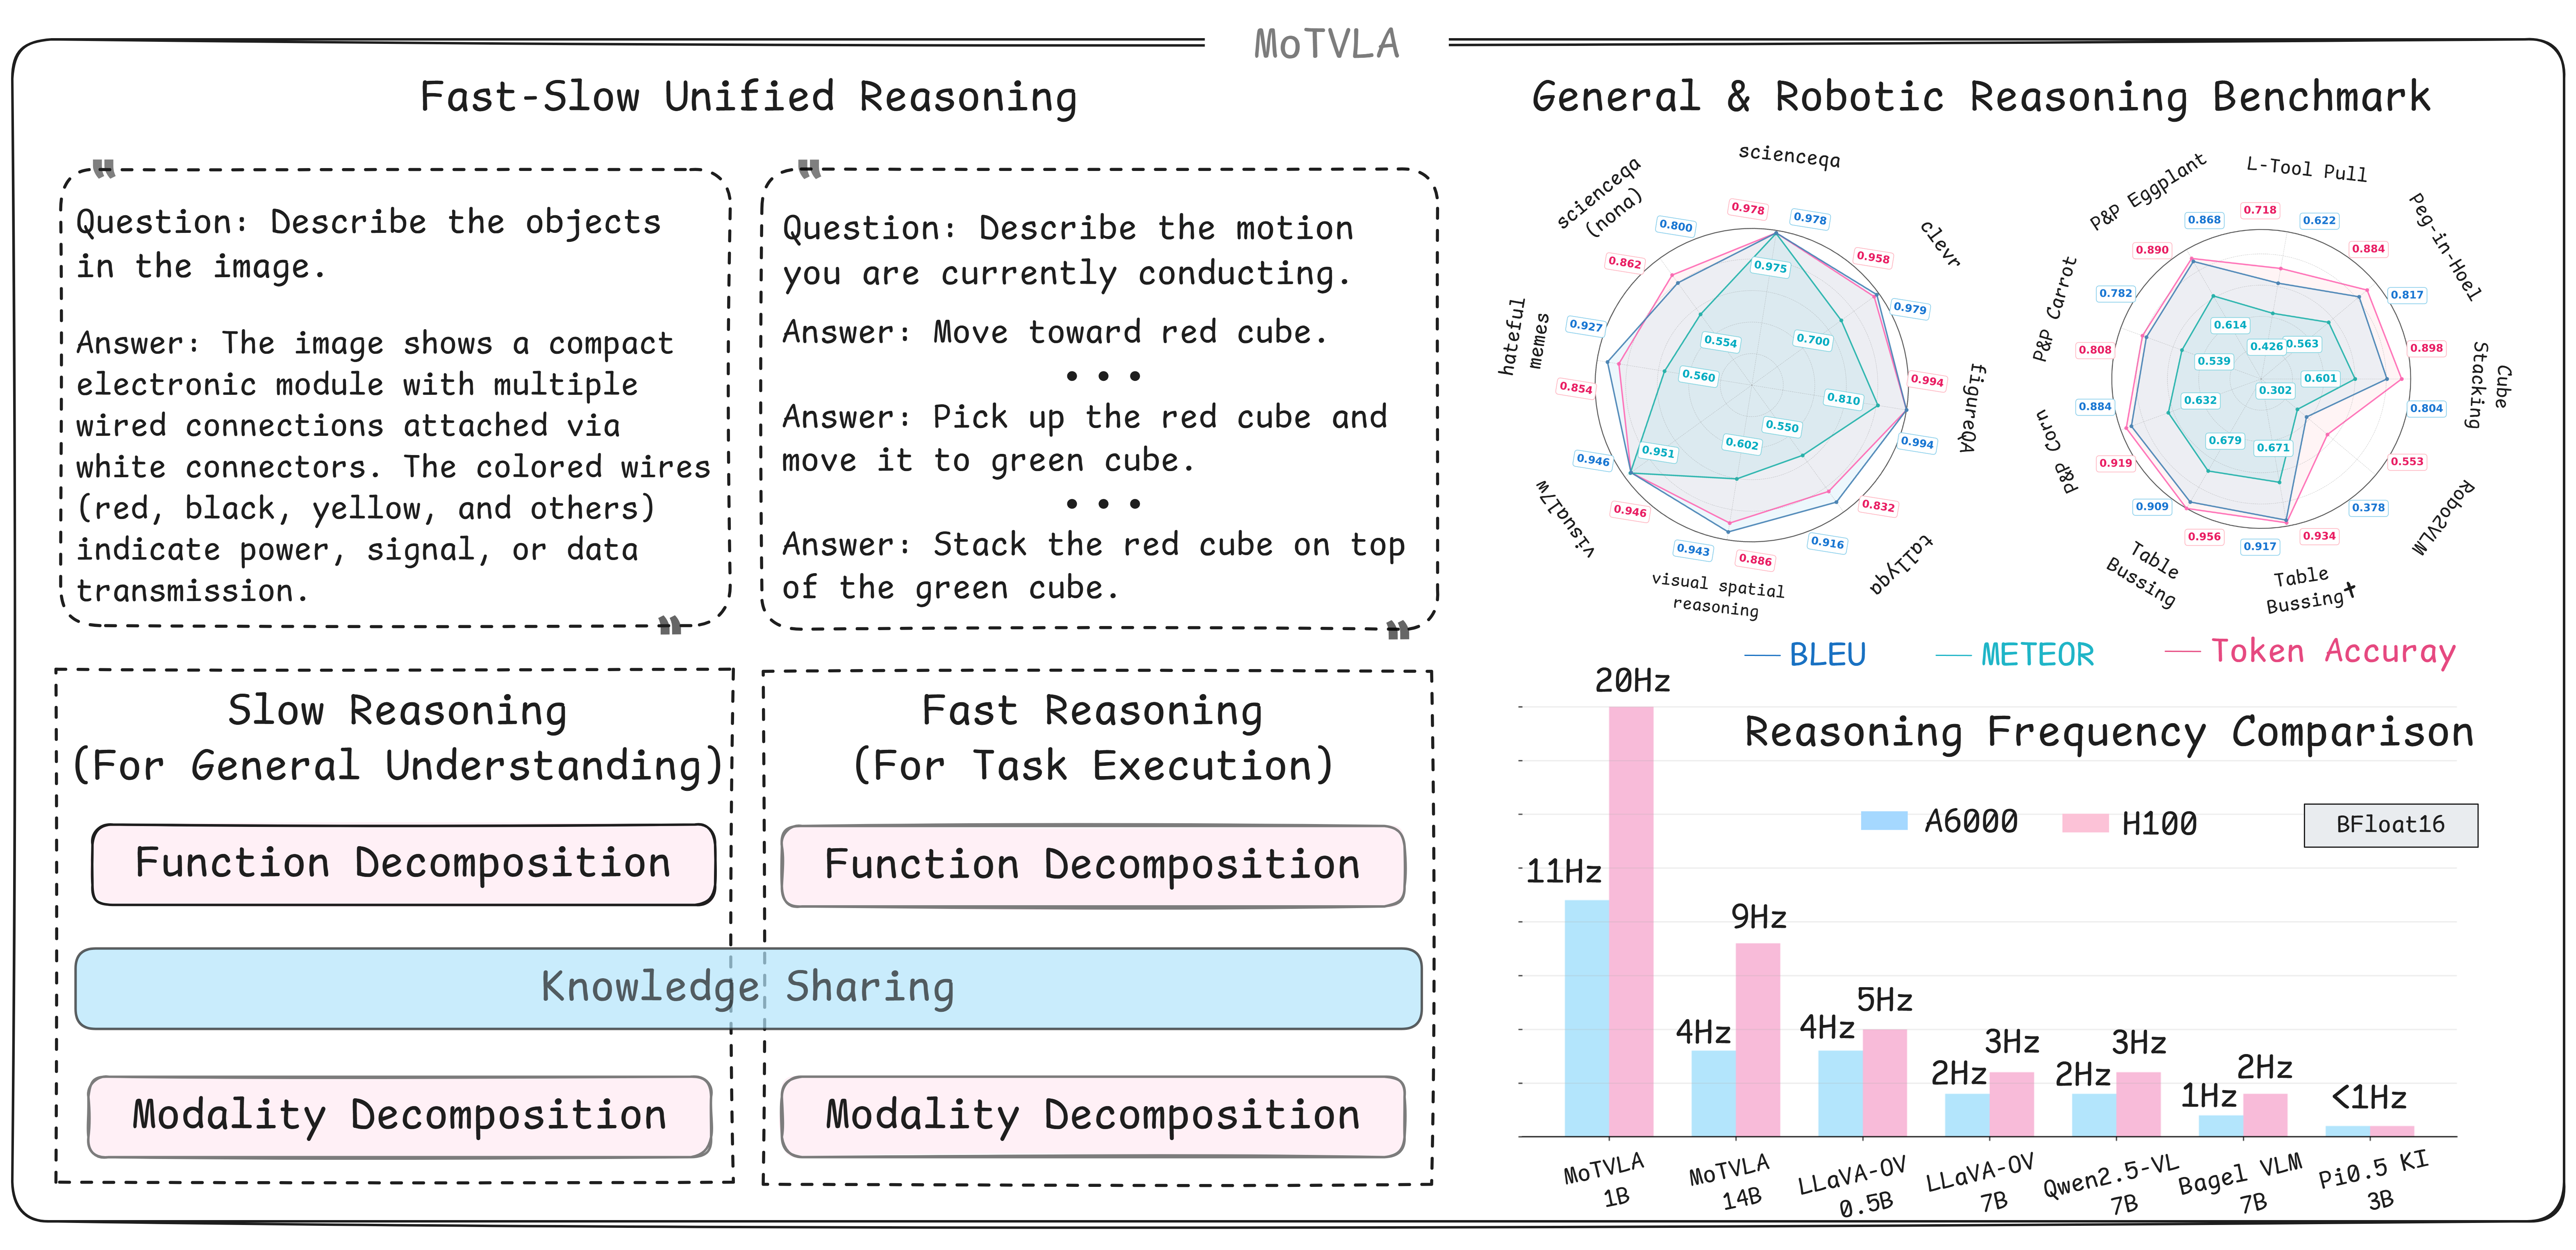
@article{huang2025motvla,title={MoTVLA: A Vision-Language-Action Model with Unified Fast-Slow Reasoning},author={Huang, Wenhui and Chen, Changhe and Qi, Han and Chen, Lv and Du, Yilun and Yang, Heng},year={2026},journal={Robotics: Science and Systems (RSS)},note={under review},}
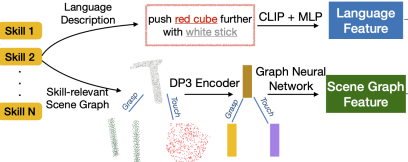
@inproceedings{qi2025compose,title={Compose by Focus: Scene Graph-based Atomic Skills},author={Qi, Han and Chen, Changhe and Yang, Heng},booktitle={IEEE International Conference on Robotics and Automation (ICRA)},year={2026},}
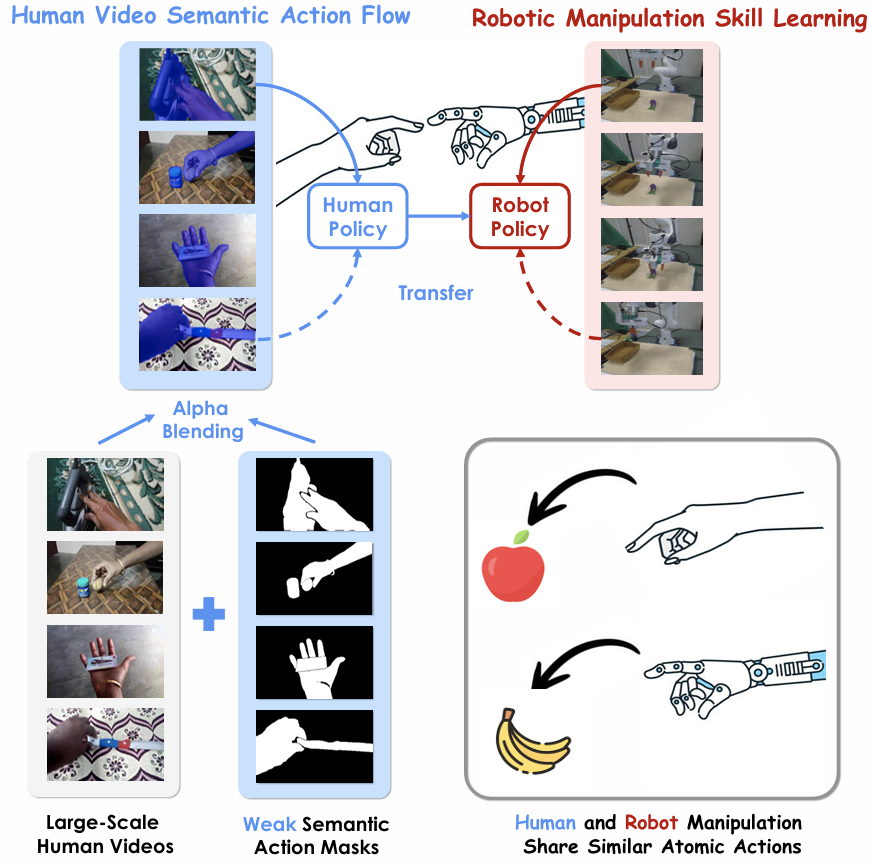
@inproceedings{chen2025visaflow,title={ViSA-Flow: Accelerating Robot Skill Learning via Large-Scale Video Semantic Action Flow},author={Chen, Changhe and Yang, Quantao and Xu, Xiaohao and Fazeli, Nima and Andersson, Olov},booktitle={IEEE International Conference on Robotics and Automation (ICRA)},year={2026},note={EgoAct workshop, Robotics: Science and Systems (RSS) 2025},}
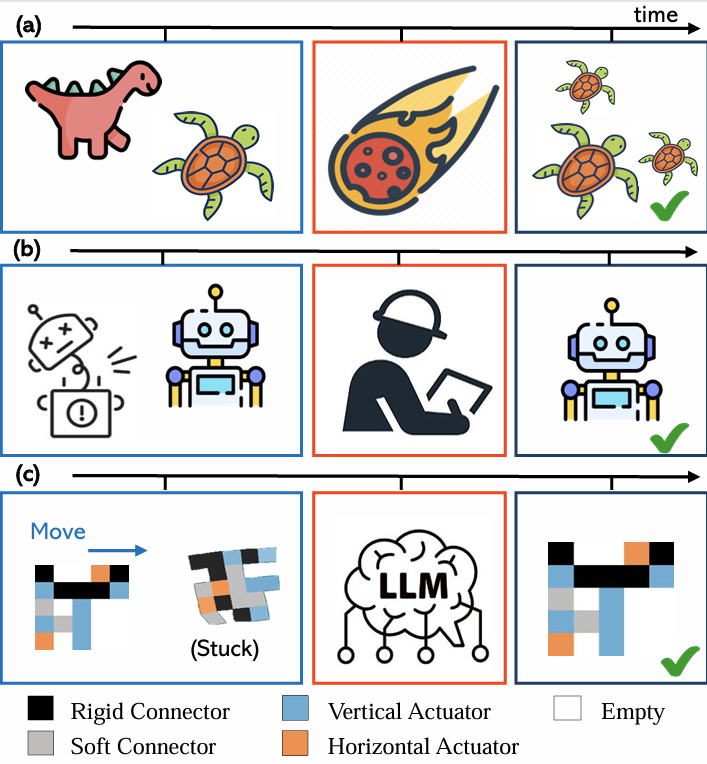
@article{chen2025softrobotdesign,title={Natural Selection via Foundation Models for Soft Robot Evolution},author={Chen, Changhe and Xu, Xiaohao and Wang, Xiangdong and Wang, Jiaqi and Huang, Xiaonan},year={2026},journal={IEEE International Conference on Soft Robotics (RoboSoft)},}
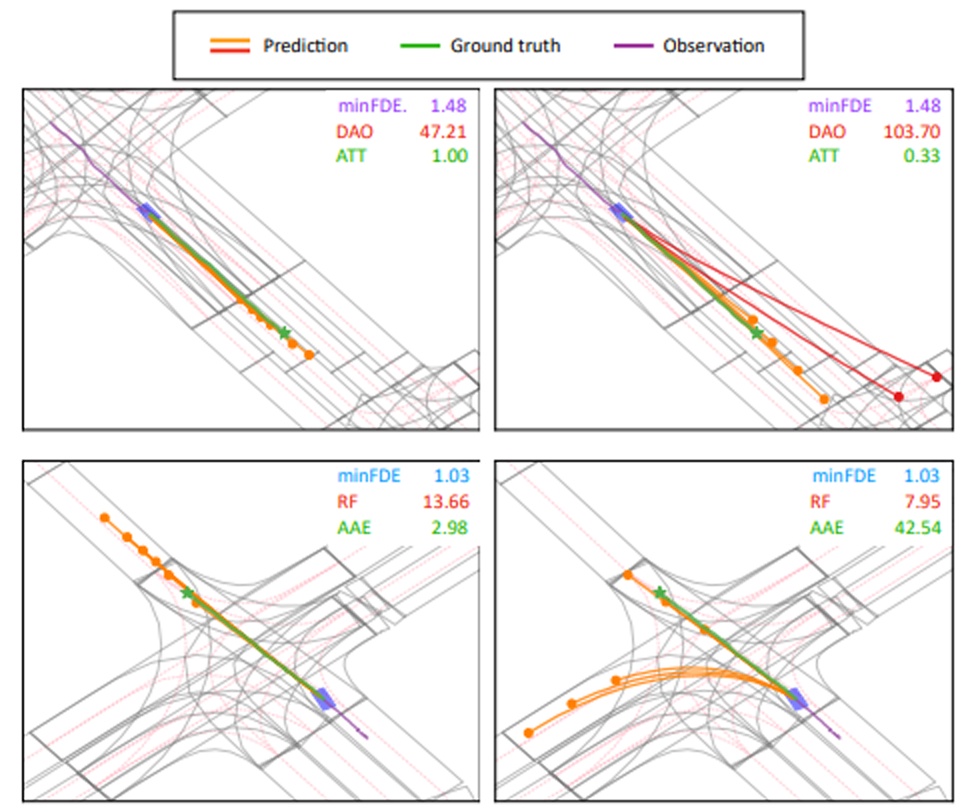
@inproceedings{chen2024criteria,title={CRITERIA: A New Benchmarking Paradigm to Evaluate Trajectory Prediction Approaches},author={Chen, Changhe and Pourkeshavarz, Mozhgan and Rasouli, Amir},booktitle={IEEE International Conference on Robotics and Automation (ICRA)},year={2024},}
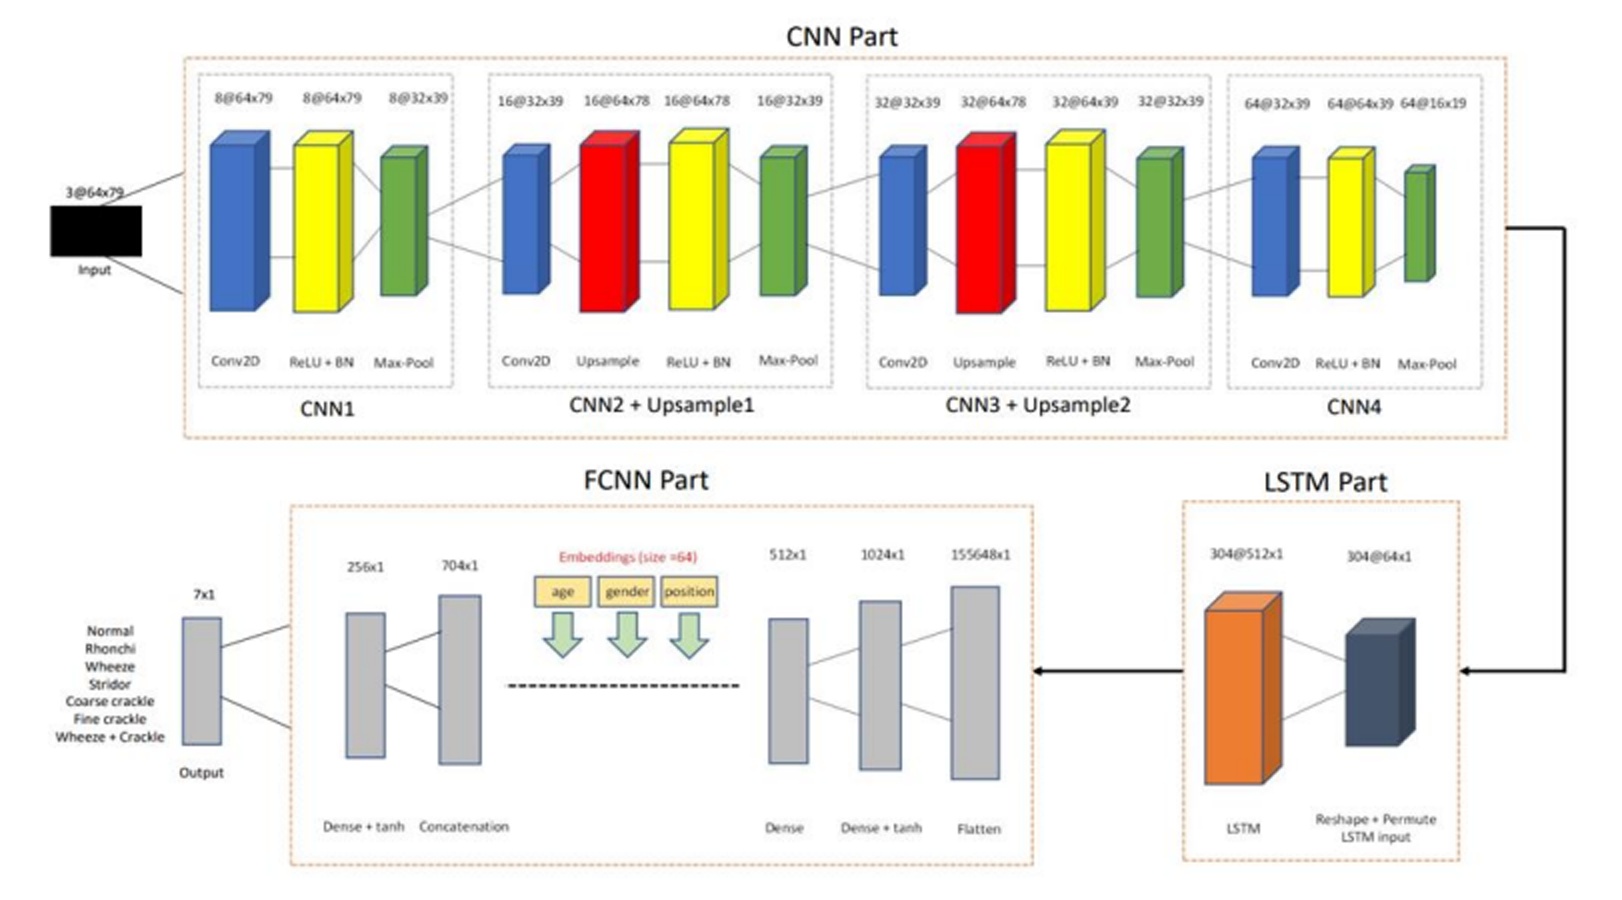
@article{chen2023respiratory,title={Using Upsampling Conv-LSTM for Respiratory Sound Classification},author={Chen, Changhe and Zhang, Rongbo},journal={Theoretical and Natural Science},year={2023},}
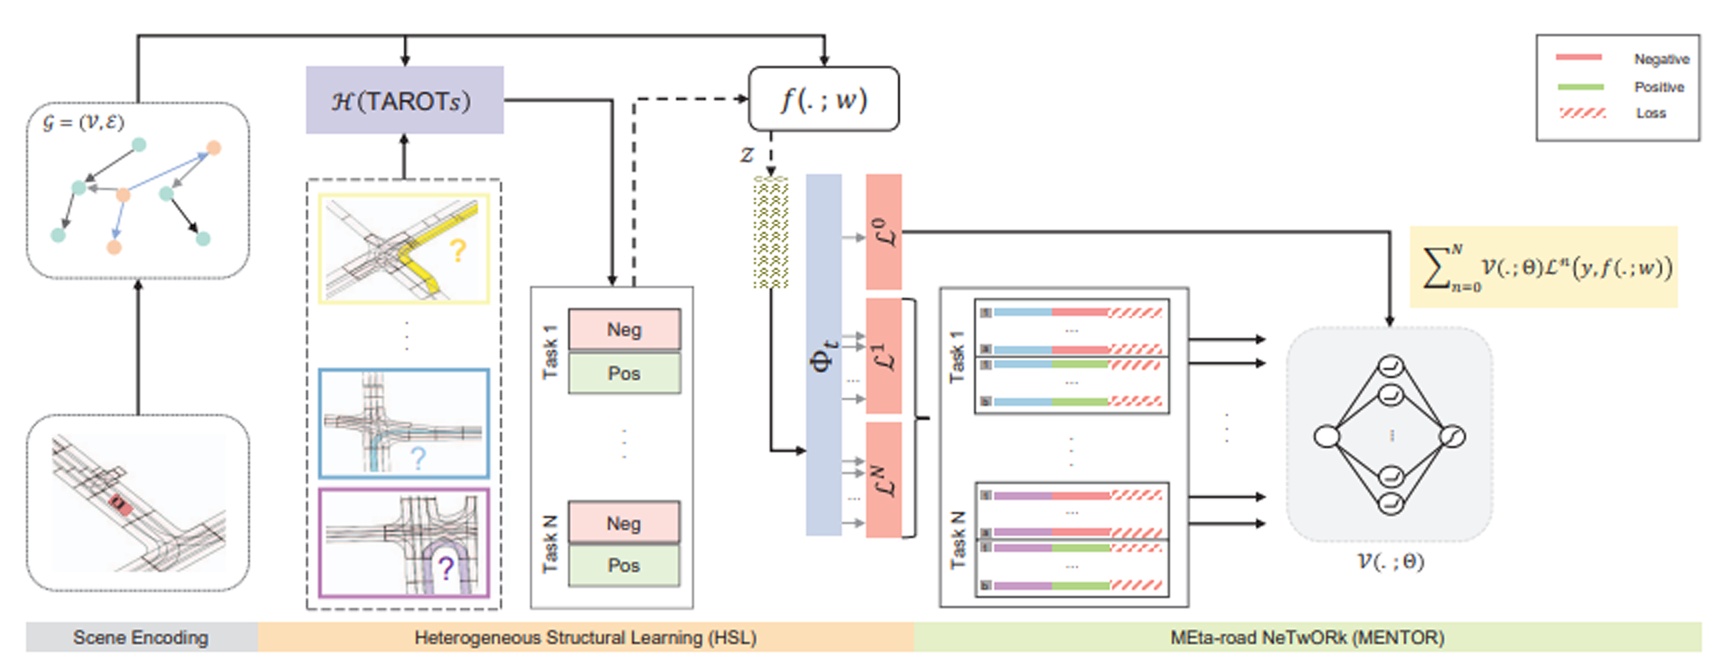
@inproceedings{pourkeshavarz2023tarot,title={Learn TAROT with MENTOR: A Meta-Learned Self-Supervised Approach for Trajectory Prediction},author={Pourkeshavarz, Mozhgan and Chen, Changhe and Rasouli, Amir},booktitle={Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV)},year={2023},}